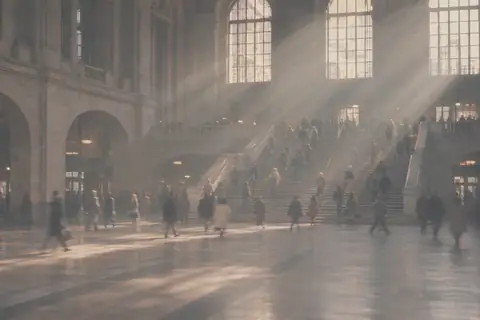
Monoid Labs
Rec · cam 01

Small models for a crowded world.

Monoid Labs is an AI research lab. We build small models that see, understand and act among people: on robots, on phones, and out on the street.

§ 01Why

Intelligence doesn’t happen in a datacenter. It happens at crossings , on platforms , in night markets and in the rain , twenty-four frames a second, among people who never stop moving. We build small models that keep up, and fit on a robot, a phone or a street corner.

§ 02How a model sees

One street, four ways of seeing it.

A camera sees light. A model has to decide, many times a second, which of it matters. Most of our work lives in that gap: getting from millions of pixels to the few things worth acting on, with a model small enough to run where the camera is.

Layer 01 / Light

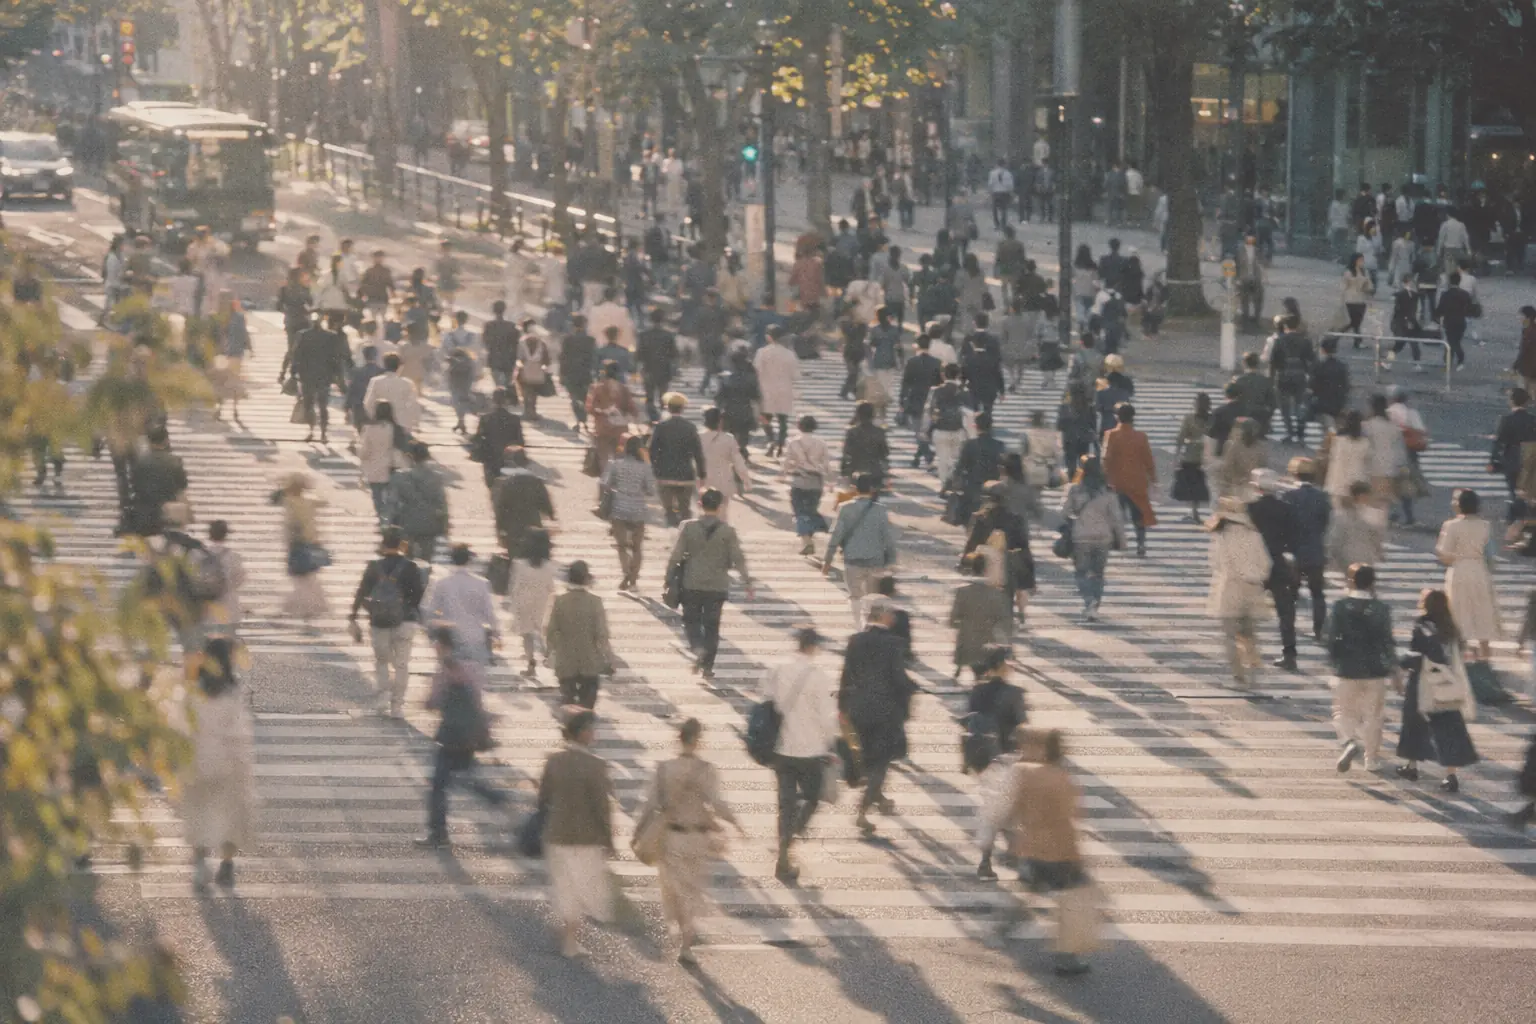
Crosswalk, late afternoon1536 × 1024 px

§ 03Contact sheet

Monoid 400▸ 1A

Crosswalk, late afternoon
Crosswalk, late afternoon01

Monoid 400▸ 2A

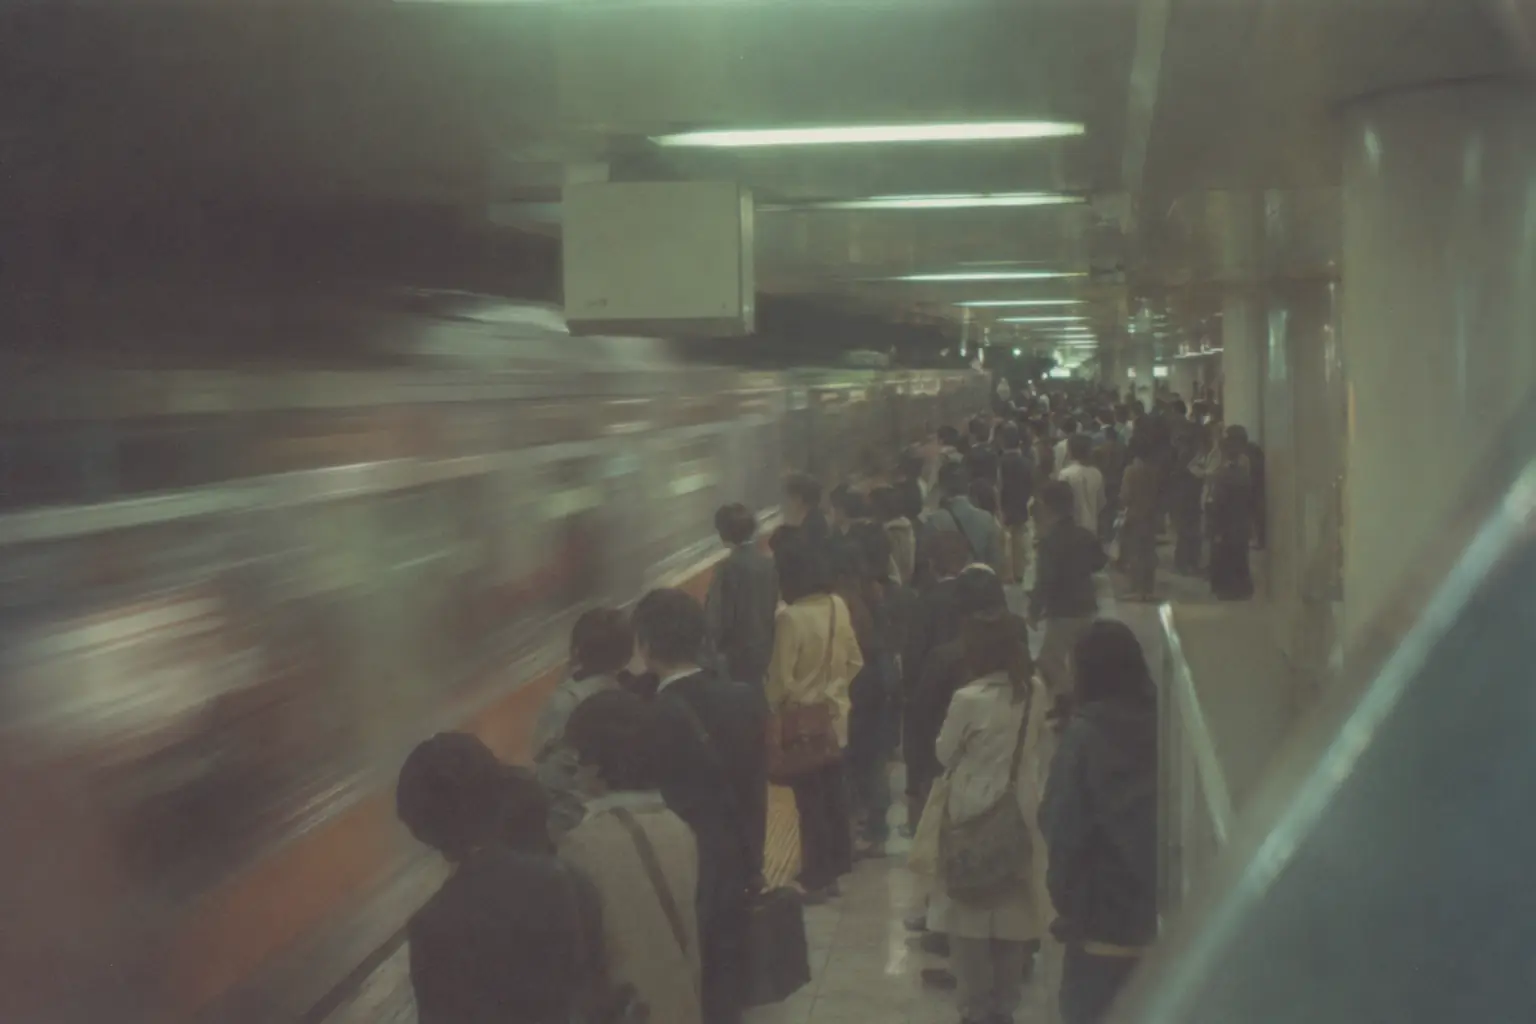
Platform, rush hour
Platform, rush hour02

Monoid 400▸ 3A

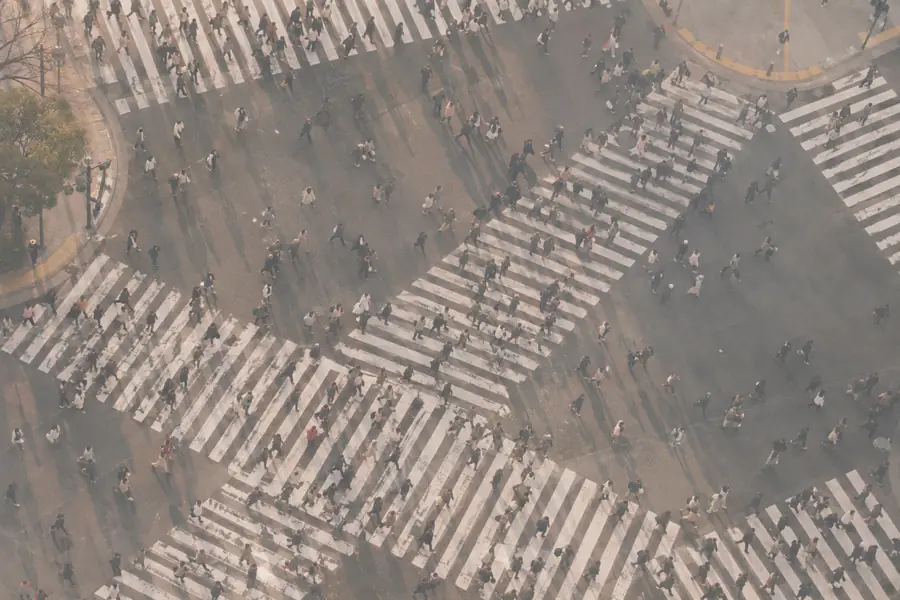
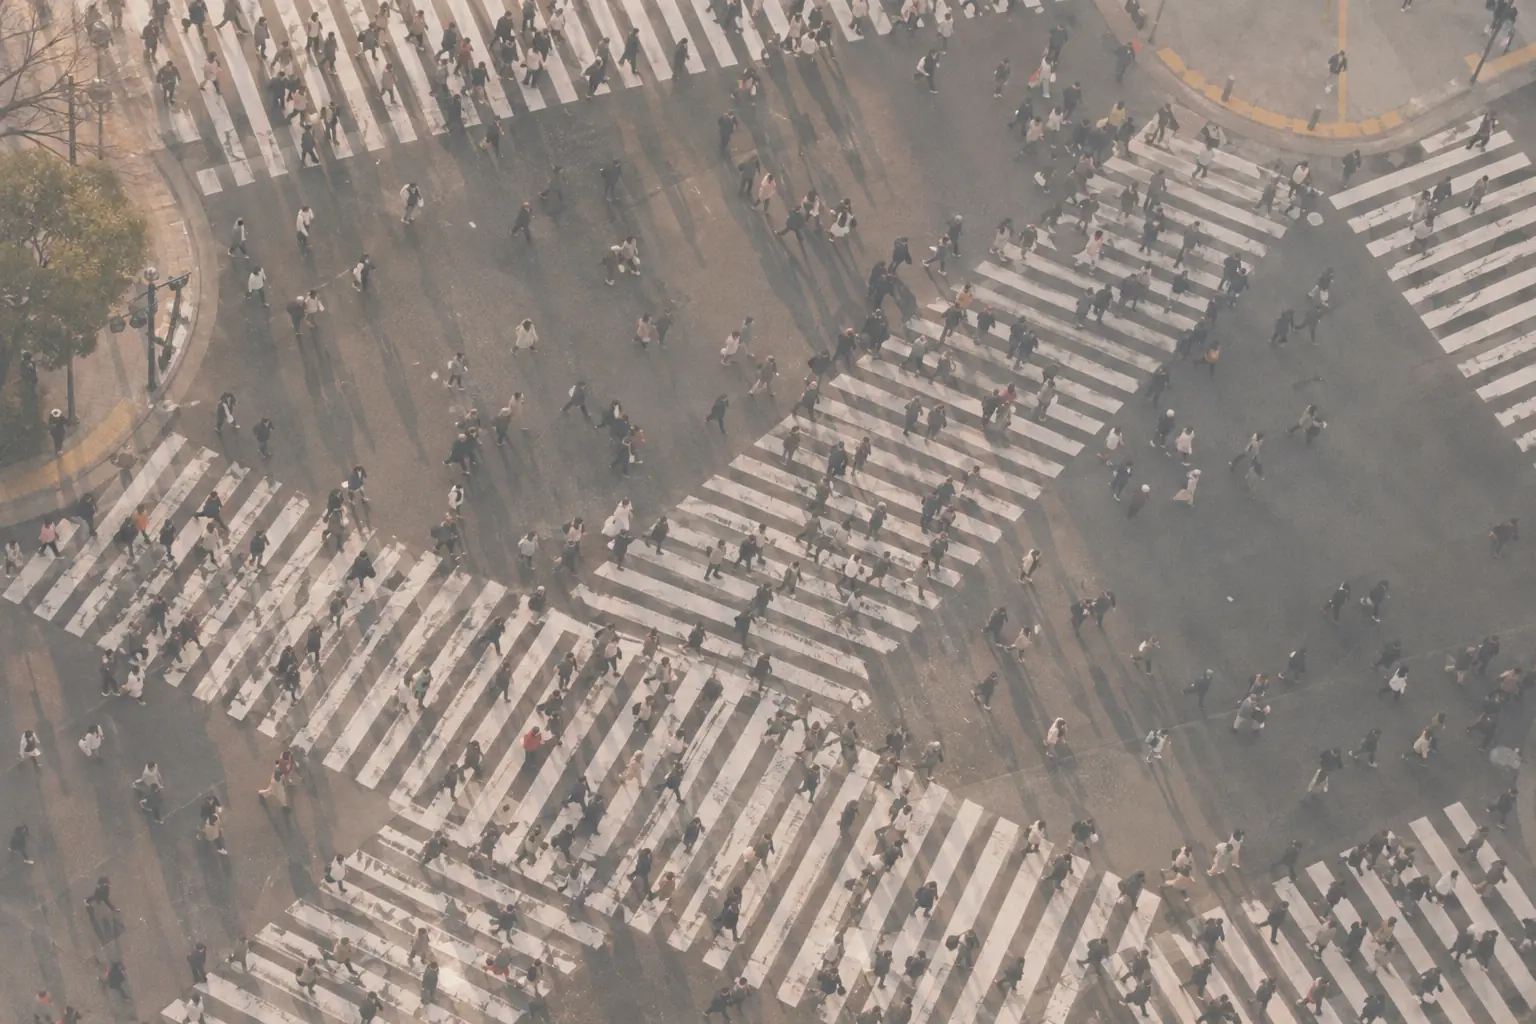
Scramble crossing, from above
Scramble crossing, from above03

Monoid 400▸ 4A

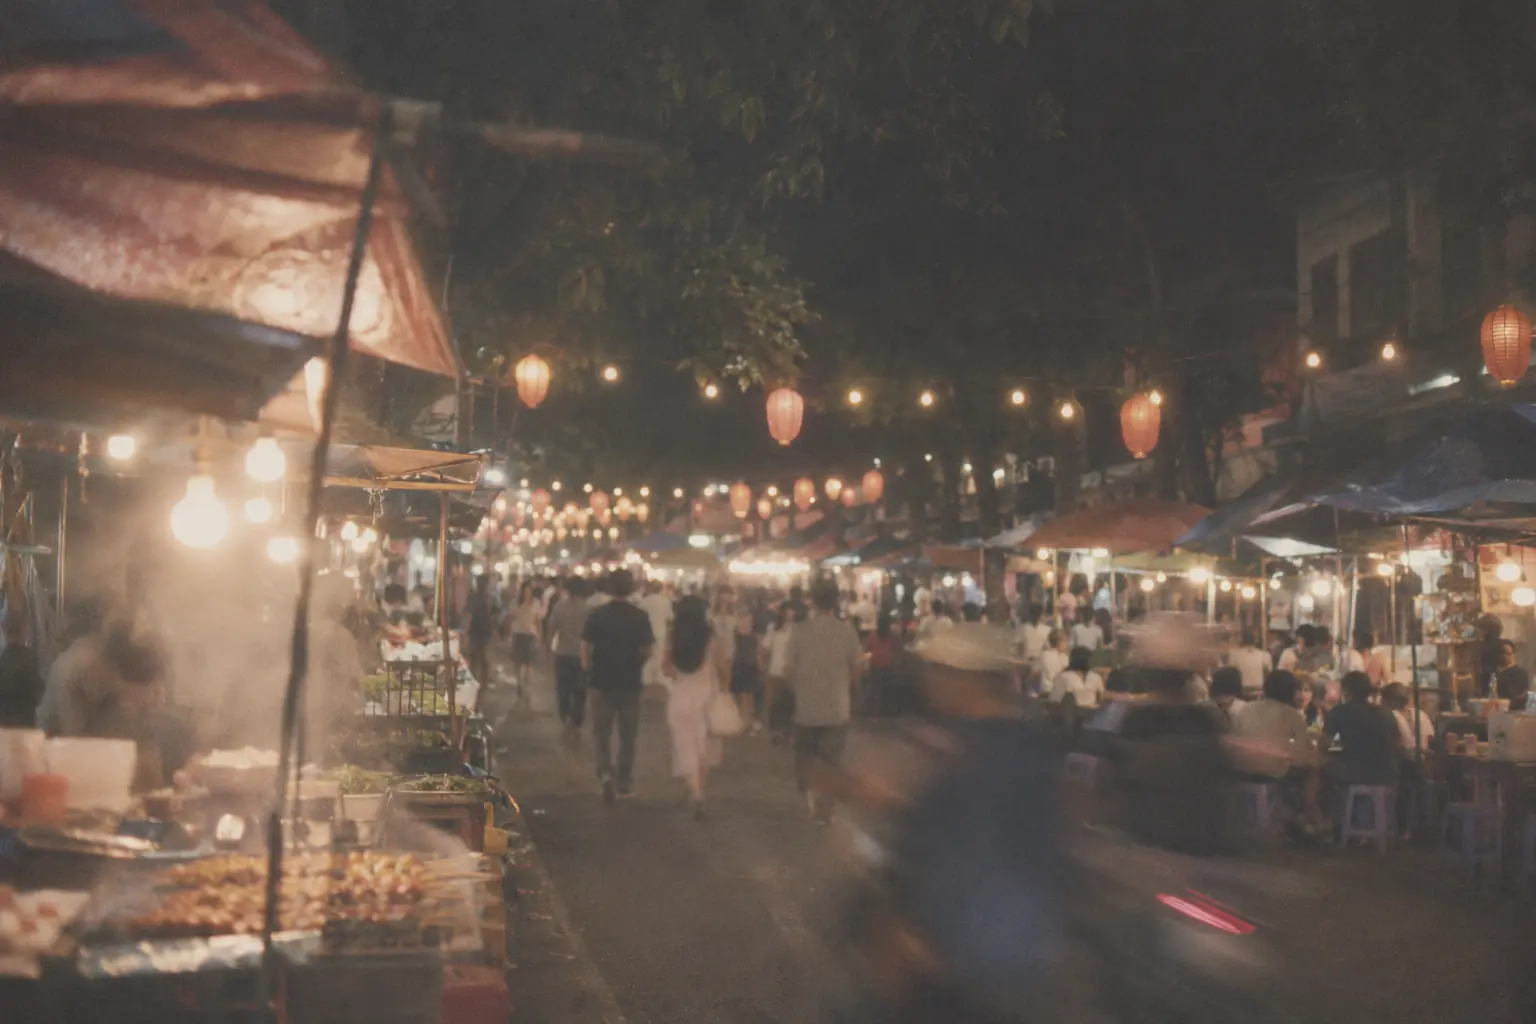
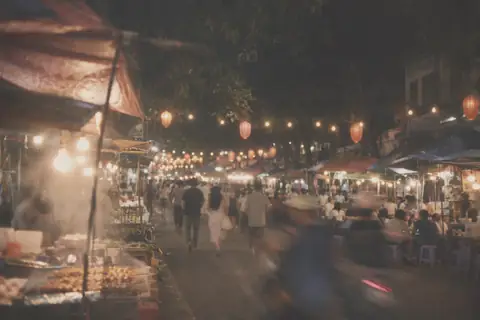
Night market
Night market04

Monoid 400▸ 5A

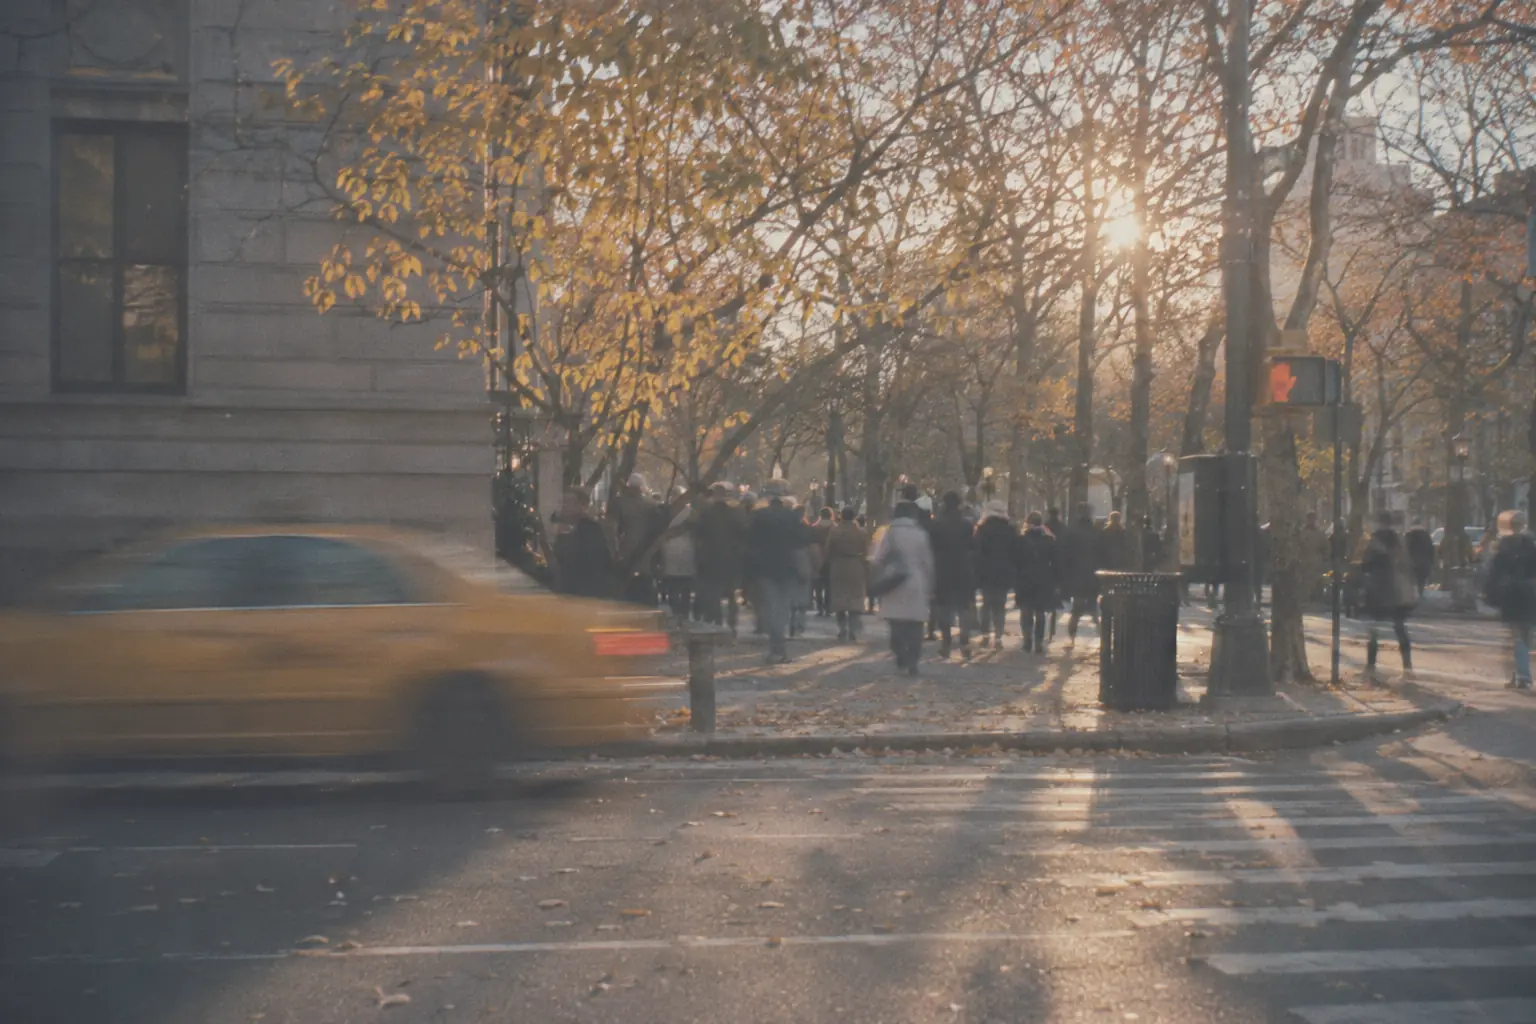
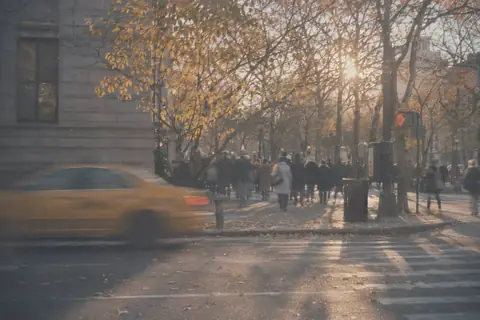
Corner, autumn
Corner, autumn05

Monoid 400▸ 6A

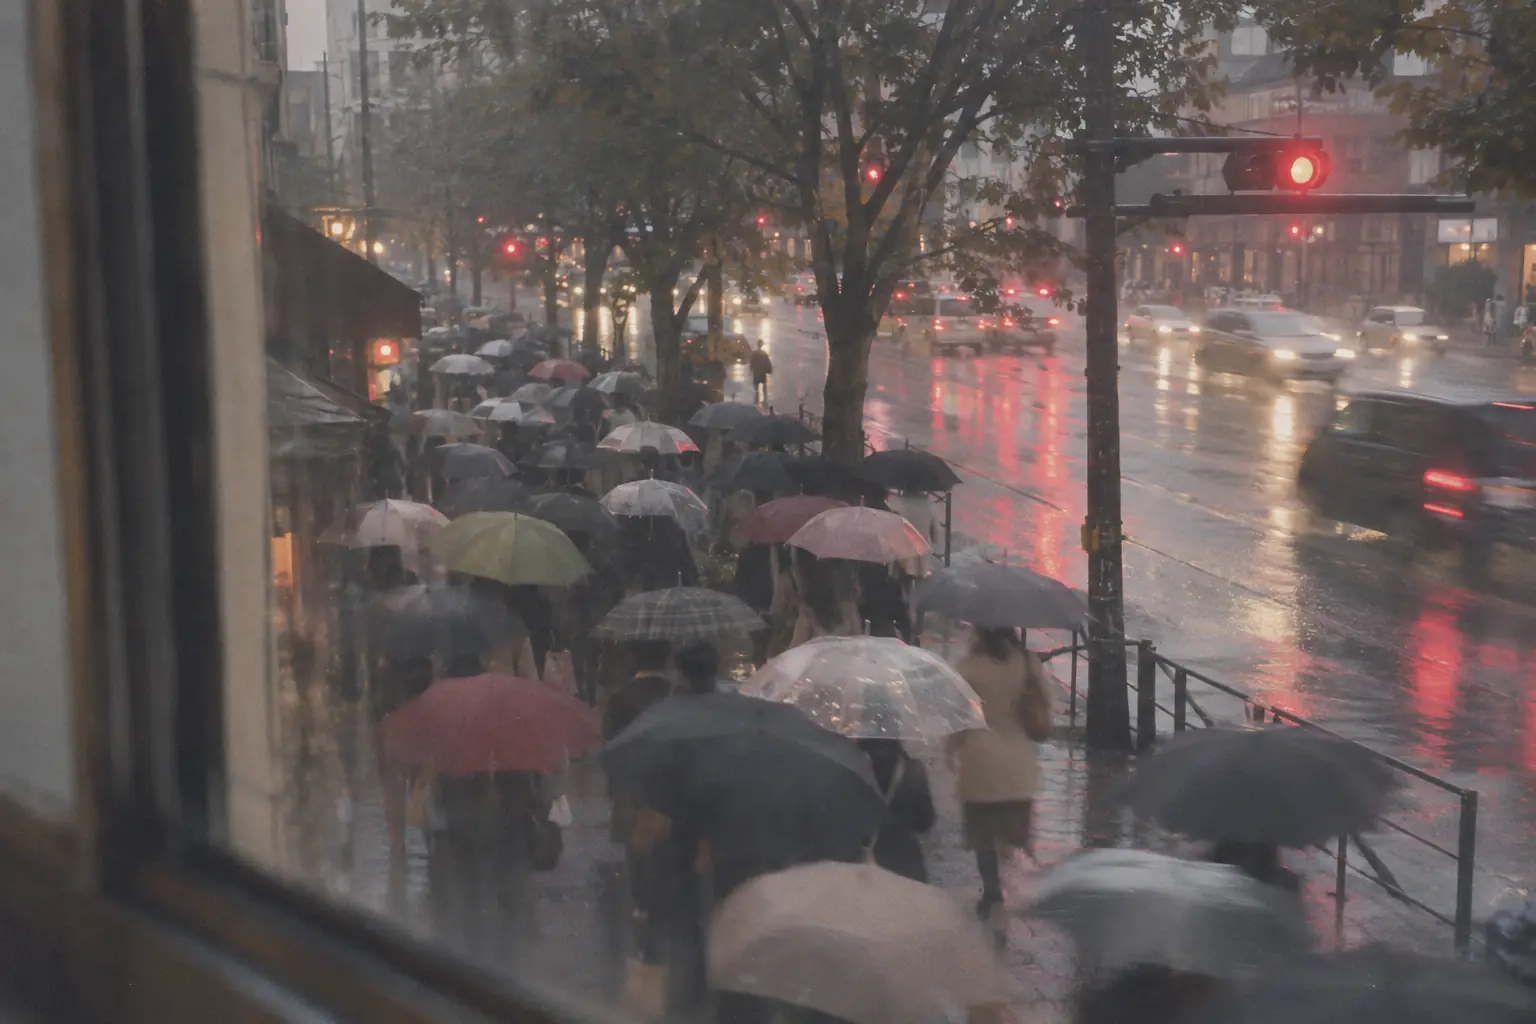
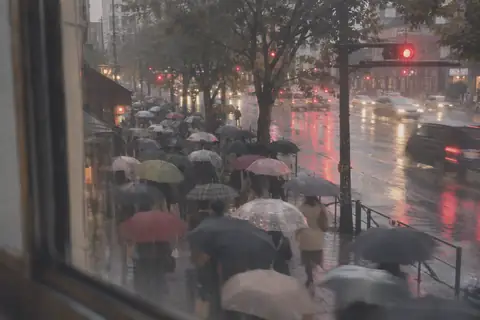
Rain, from the first floor
Rain, from the first floor06

Monoid 400▸ 7A

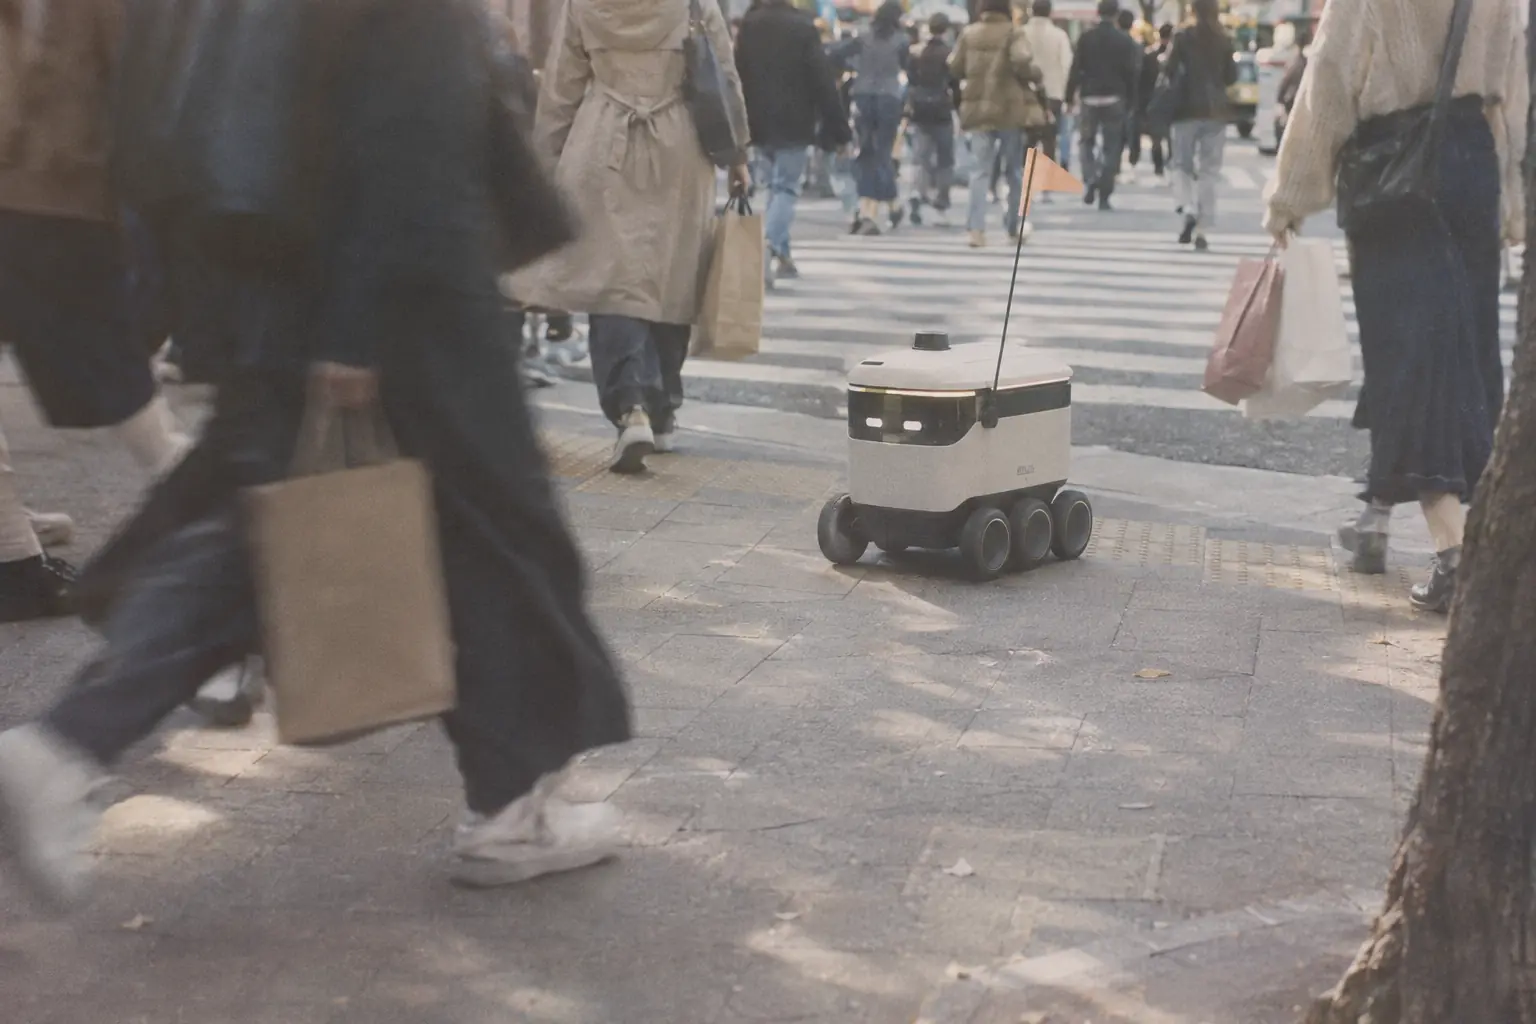
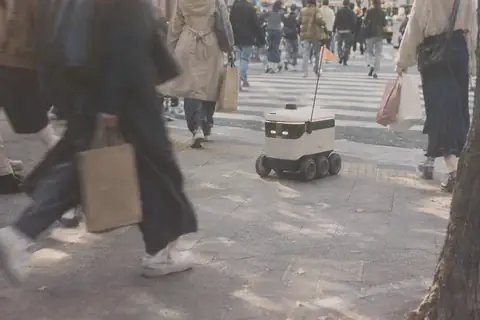
Delivery robot, waiting to cross
Delivery robot, waiting to cross07

Monoid 400▸ 8A

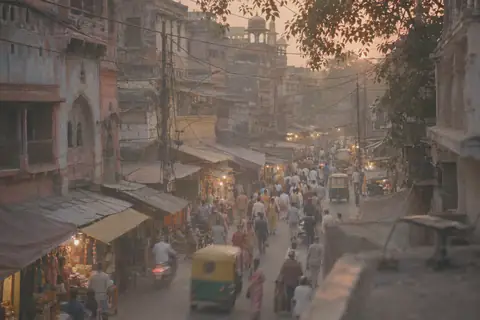
Old-city bazaar
Old-city bazaar08

Monoid 400▸ 9A

Station stairs
Station stairs09

Monoid 400▸ 10A

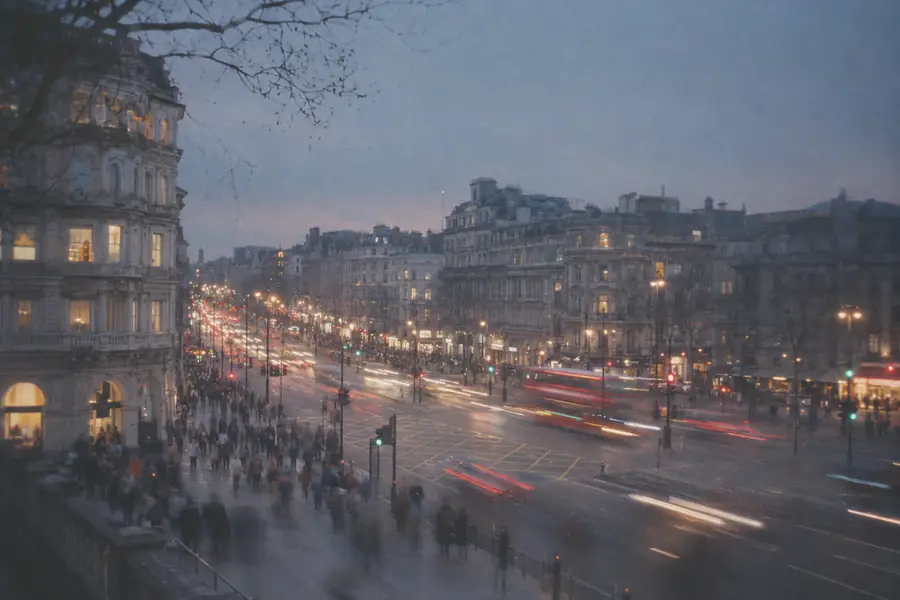
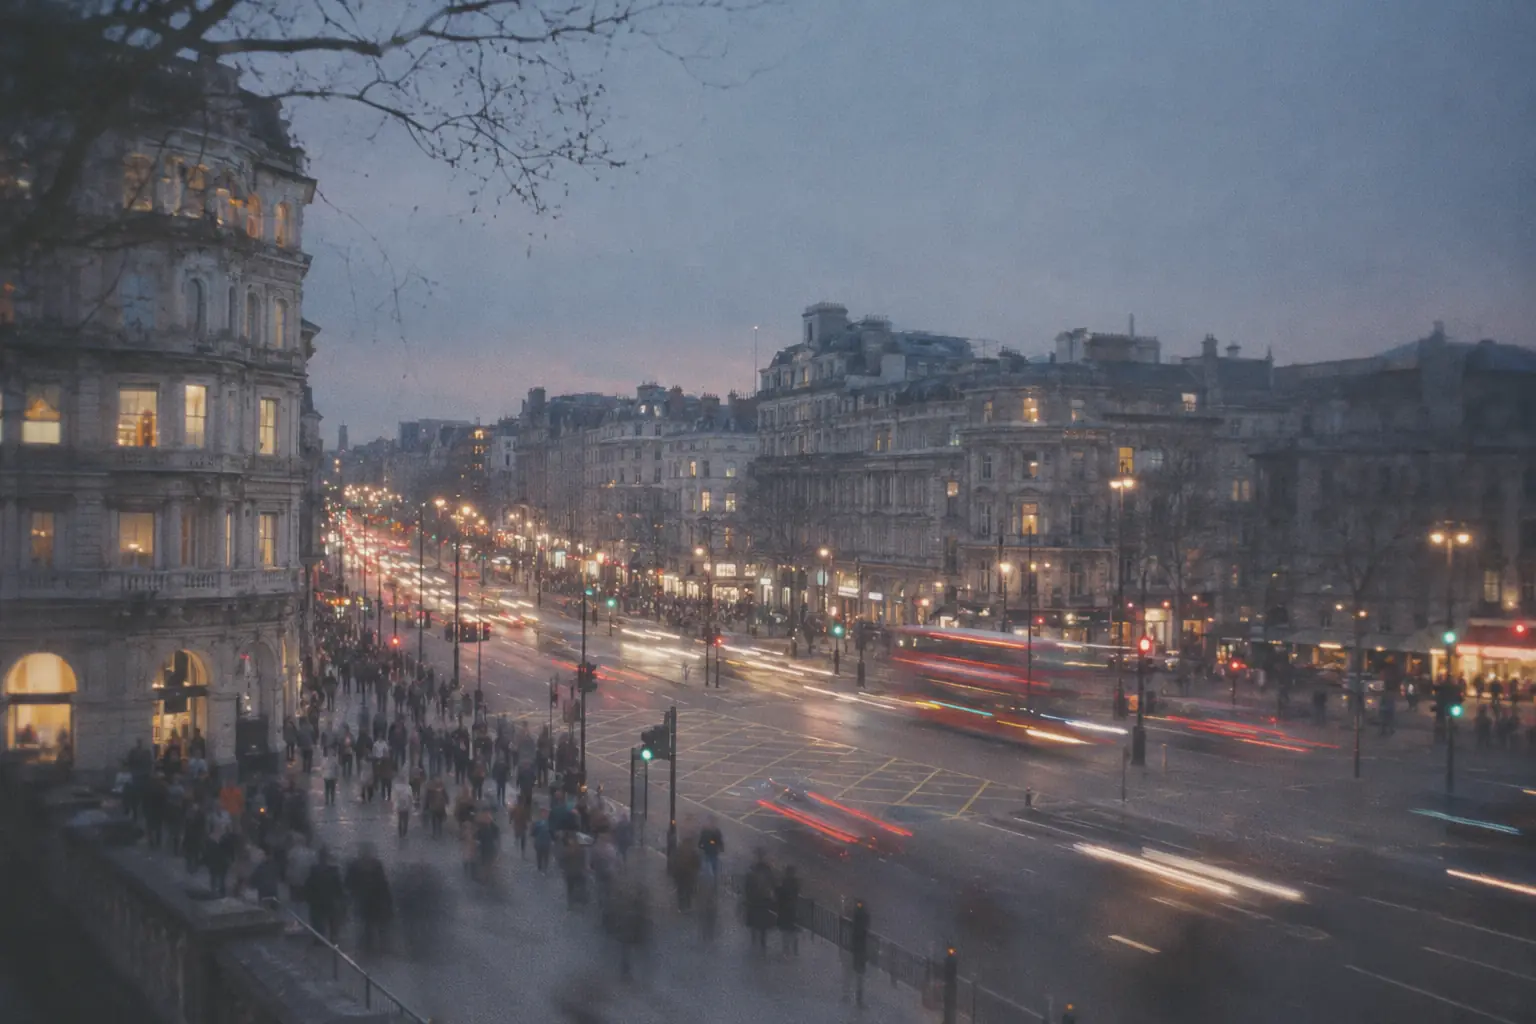
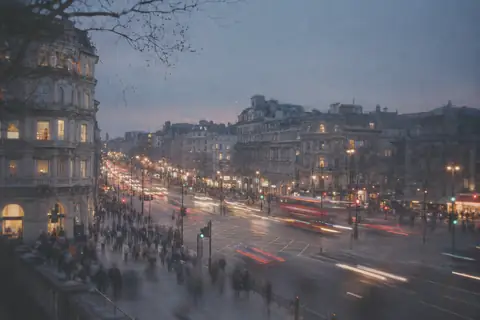
Intersection, blue hour
Intersection, blue hour10

Monoid 400▸ 11A

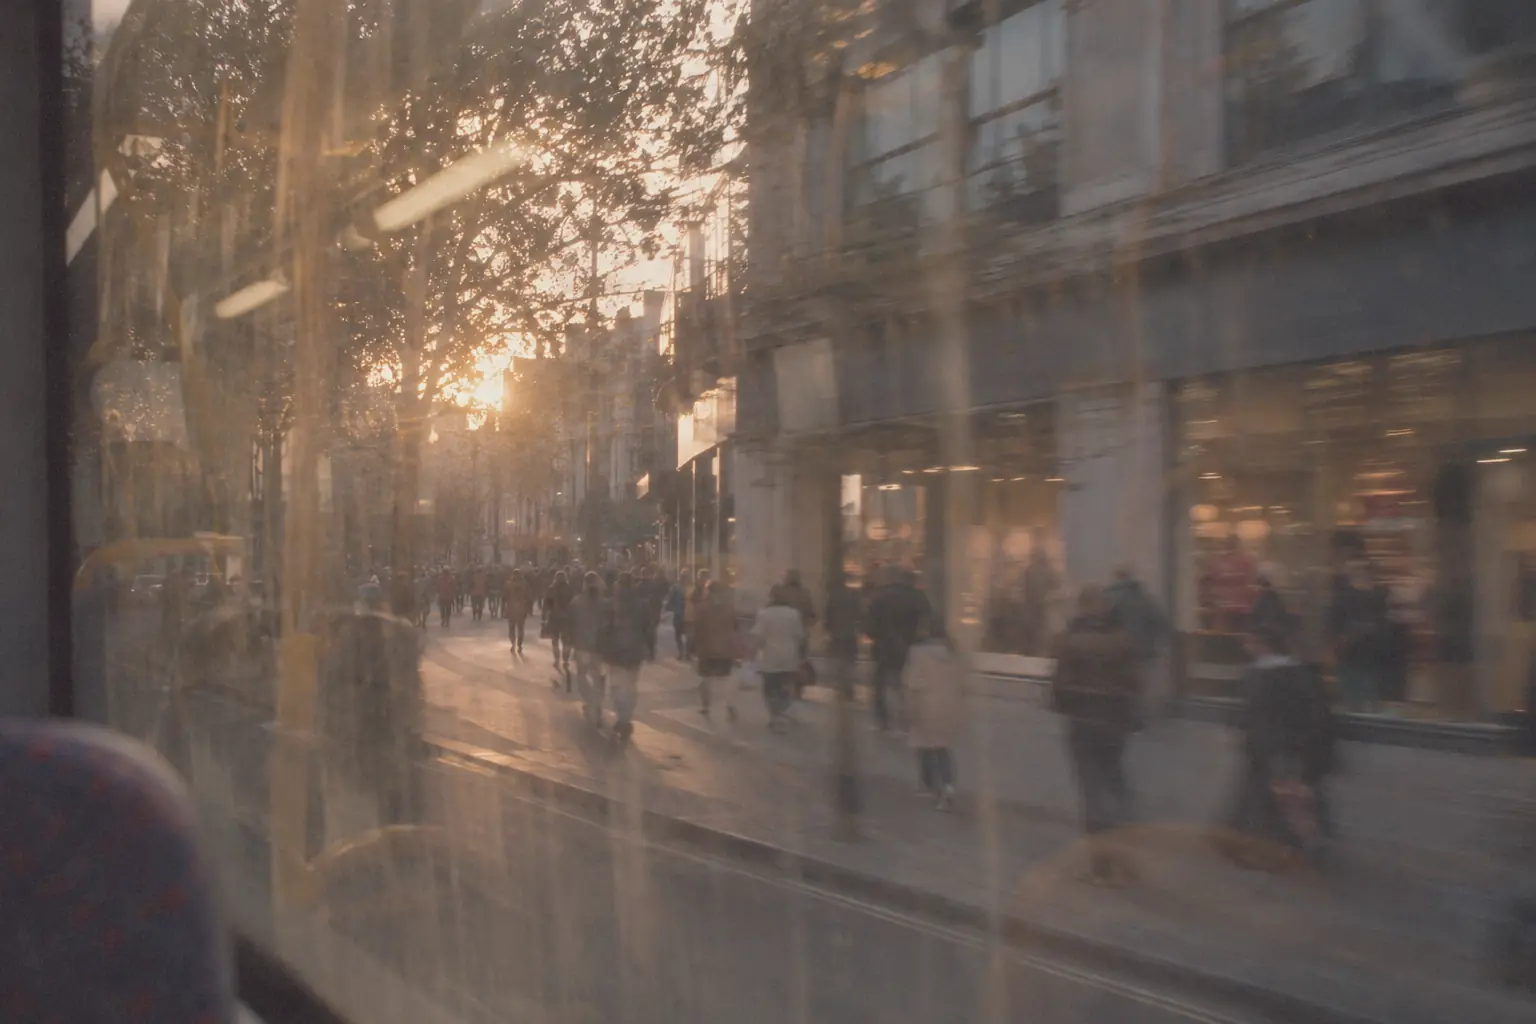
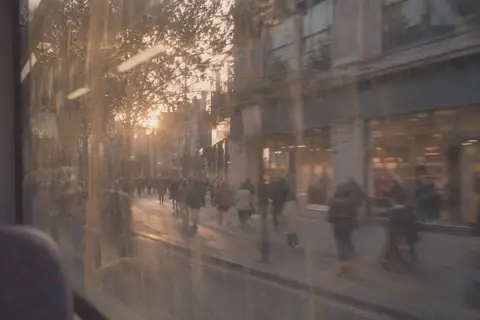
Through the bus window
Through the bus window11

Monoid 400▸ 12A

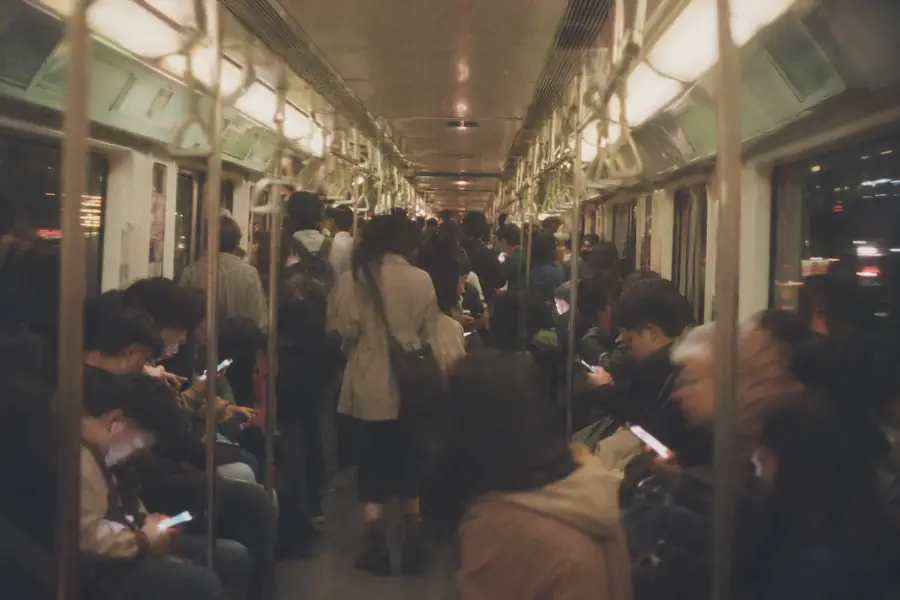
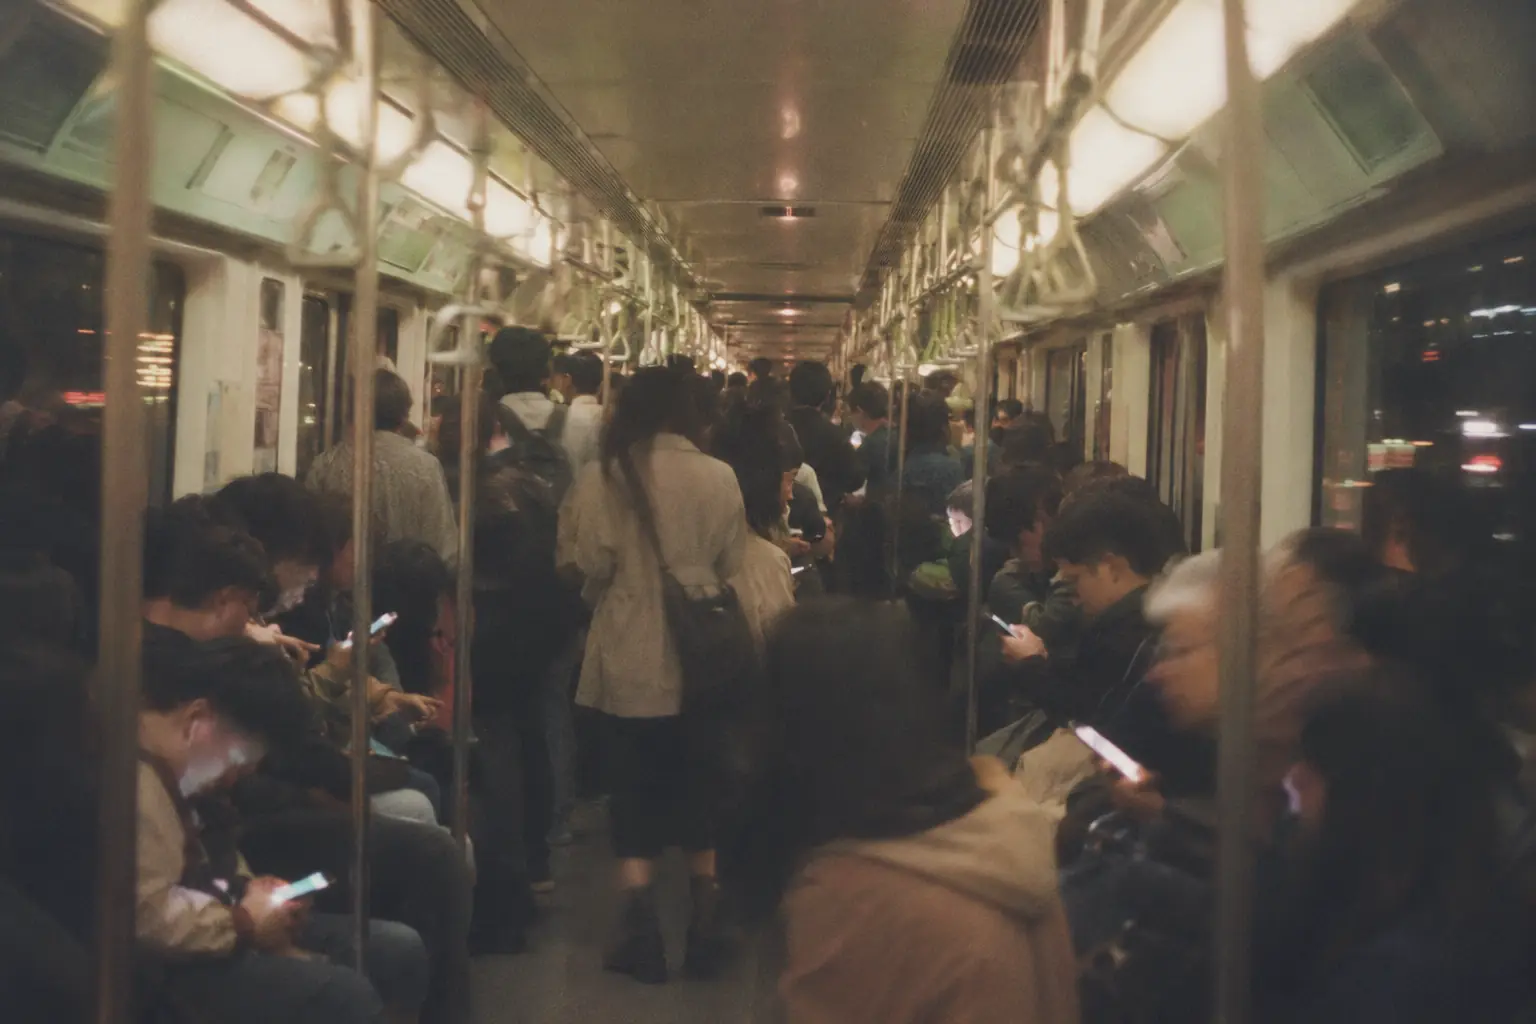
Last train home
Last train home12

Monoid 400▸ 13A

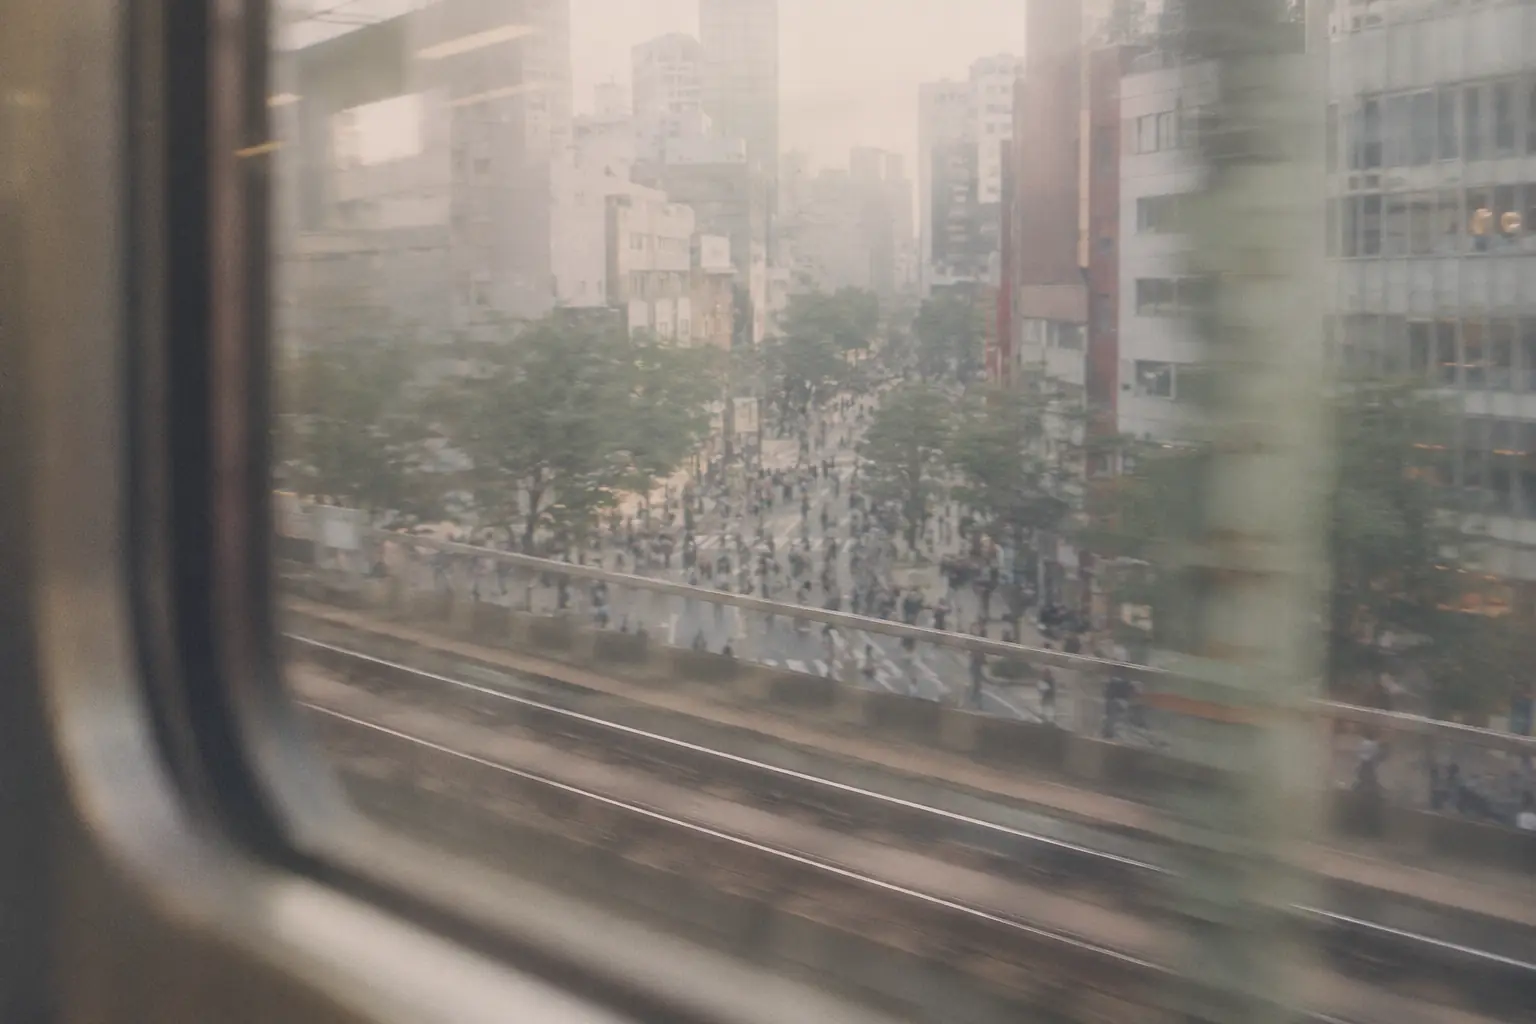
From the elevated line
From the elevated line13

Monoid 400▸ 14A

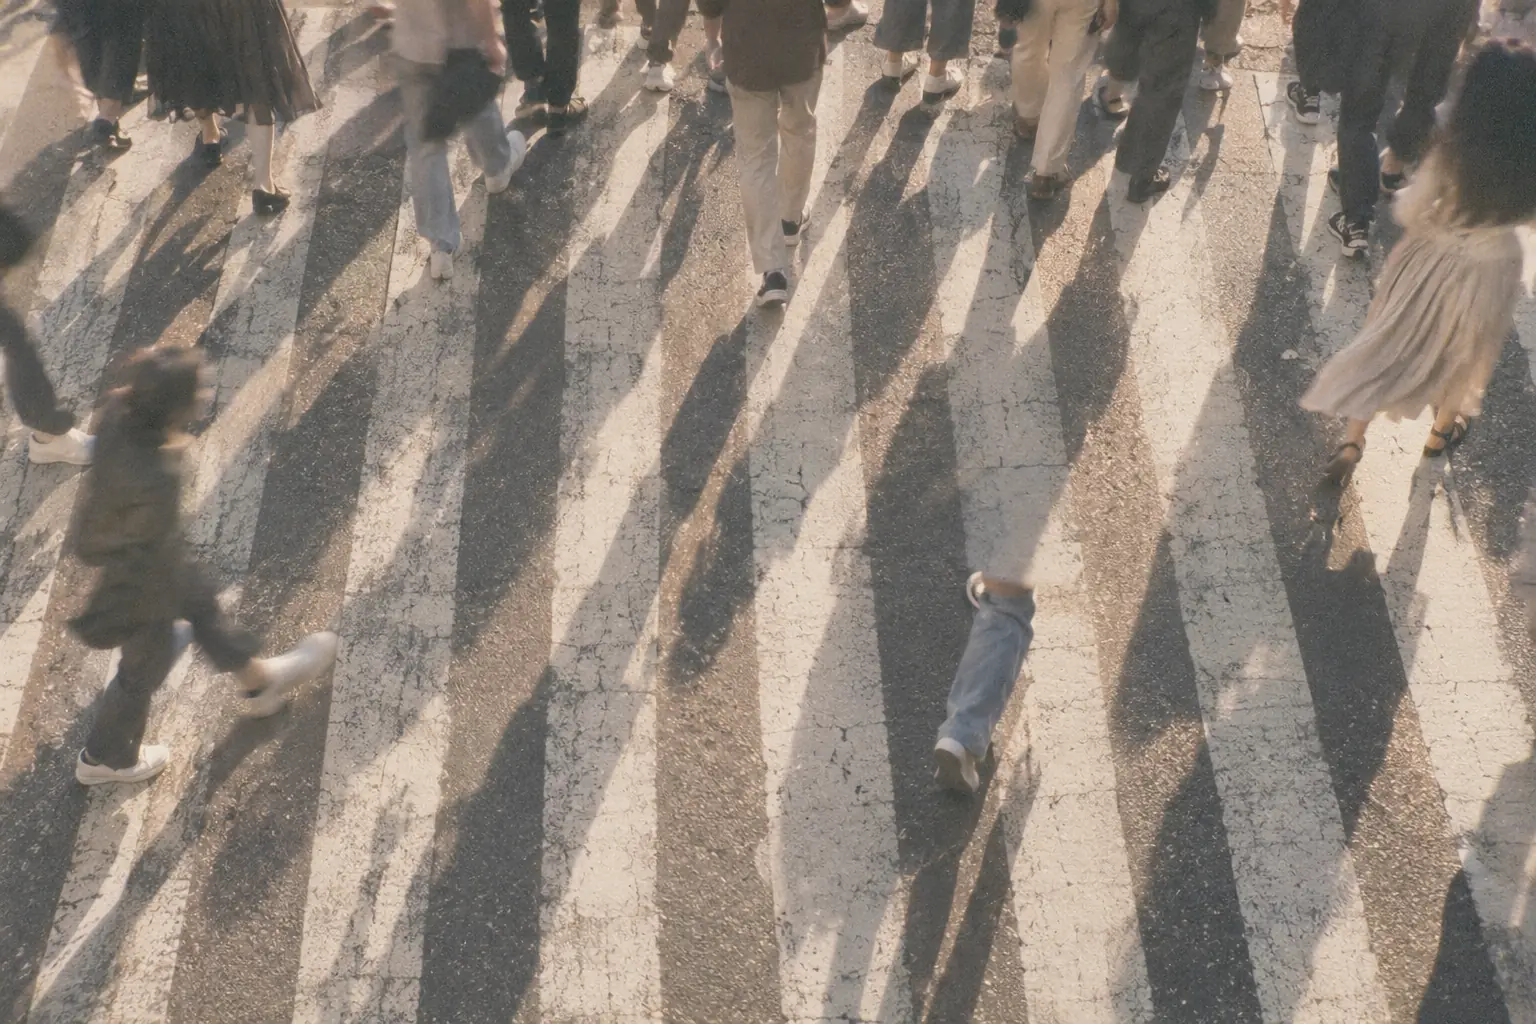
Shadows on the stripes
Shadows on the stripes14

§ 04Research

Four directions, one street.

Delivery robot, waiting to cross01Robotics

Robots and VLA models

Vision-language-action models that take in camera frames and an instruction and put out motor commands. We study how to pre-train them on web and robot data, and how to adapt them to a new body or task from a few demonstrations.

  • VLA
  • manipulation
  • navigation
  • few-shot
Last train home02Efficiency

Small models

Models that run on a robot's onboard computer, a laptop or a phone, and that groups without a frontier budget can study. Distillation, data selection, and architectures that keep capability as parameters get scarce.

  • distillation
  • on-device
  • data
  • architecture
Scramble crossing, from above03Foundations

Learning algorithms

Optimisation, reinforcement learning and search methods that make training cheaper, steadier and easier to reason about. We prefer methods whose assumptions can be checked, and we report the runs that fail.

  • optimisation
  • RL
  • search
  • evaluation
Intersection, blue hour04Agents

Agents and RL

Agents that work over long horizons in real software, trained with reinforcement learning on real sessions and runnable environments. This is the home of OpenRL, our open corpus of consented agent trajectories.

  • long horizon
  • environments
  • rewards
  • OpenRL

§ 05Projects

Real work, from real people.

OpenRL is our open, consented corpus of real coding-agent sessions and runnable environments. Agents get better by learning from real work; OpenRL lets universities, sovereign AI labs and open model builders learn from the same kind of work as the companies that run them.

Sources
Real sessions from Claude Code, Codex, Cursor, Antigravity and OpenCode
Privacy
Redacted on the contributor's machine, approved by them, scanned again on receipt
Access
Versioned releases for approved researchers, each with a data card

Contributors use the Monoid app for macOS, Windows and Linux. It finds agent sessions on your machine, redacts them locally, and asks you to approve each one.

Shadows on the stripes · halftone

Every dot is a value

§ 06Principles

How we work.

  1. 01

    Small by default

    We look for the smallest model that does the job, then try to make it smaller. Small models fit on robots and phones, and more people can afford to study them.

  2. 02

    Judged by what it does

    Language is not the end of the task. We evaluate models on outcomes: code that runs, grasps that hold, crossings made safely.

  3. 03

    Built to compose

    Perception, language and control with clean interfaces between them, so an improvement in one part carries to the rest. That is the monoid in the name.

  4. 04

    Measured, not claimed

    Every result ships with the evaluation that produced it, the baselines it beats, and the runs that failed.

  5. 05

    Made for the street

    Real places are crowded, badly lit and always changing. We test for that, not only for the benchmark.

  6. 06

    Consent first

    Data that comes from people is collected with their consent and can be withdrawn. OpenRL was built that way from the start.

§ 07Join

Come build with us.

Researchers and engineers

If you work on robot learning, small models or RL and want to do it in the open, write to us with something you have built.

hello@monoidlabs.ai

Universities and labs

Co-design evaluations with us, use OpenRL data in your research, or tell us which environments would make it more useful.

Apply for OpenRL data

Funders and partners

We are seeking research grants, compute and institutional partners for open data, evaluations and releases.

partners@monoidlabs.ai